ME100 Project: RC Fire Truck
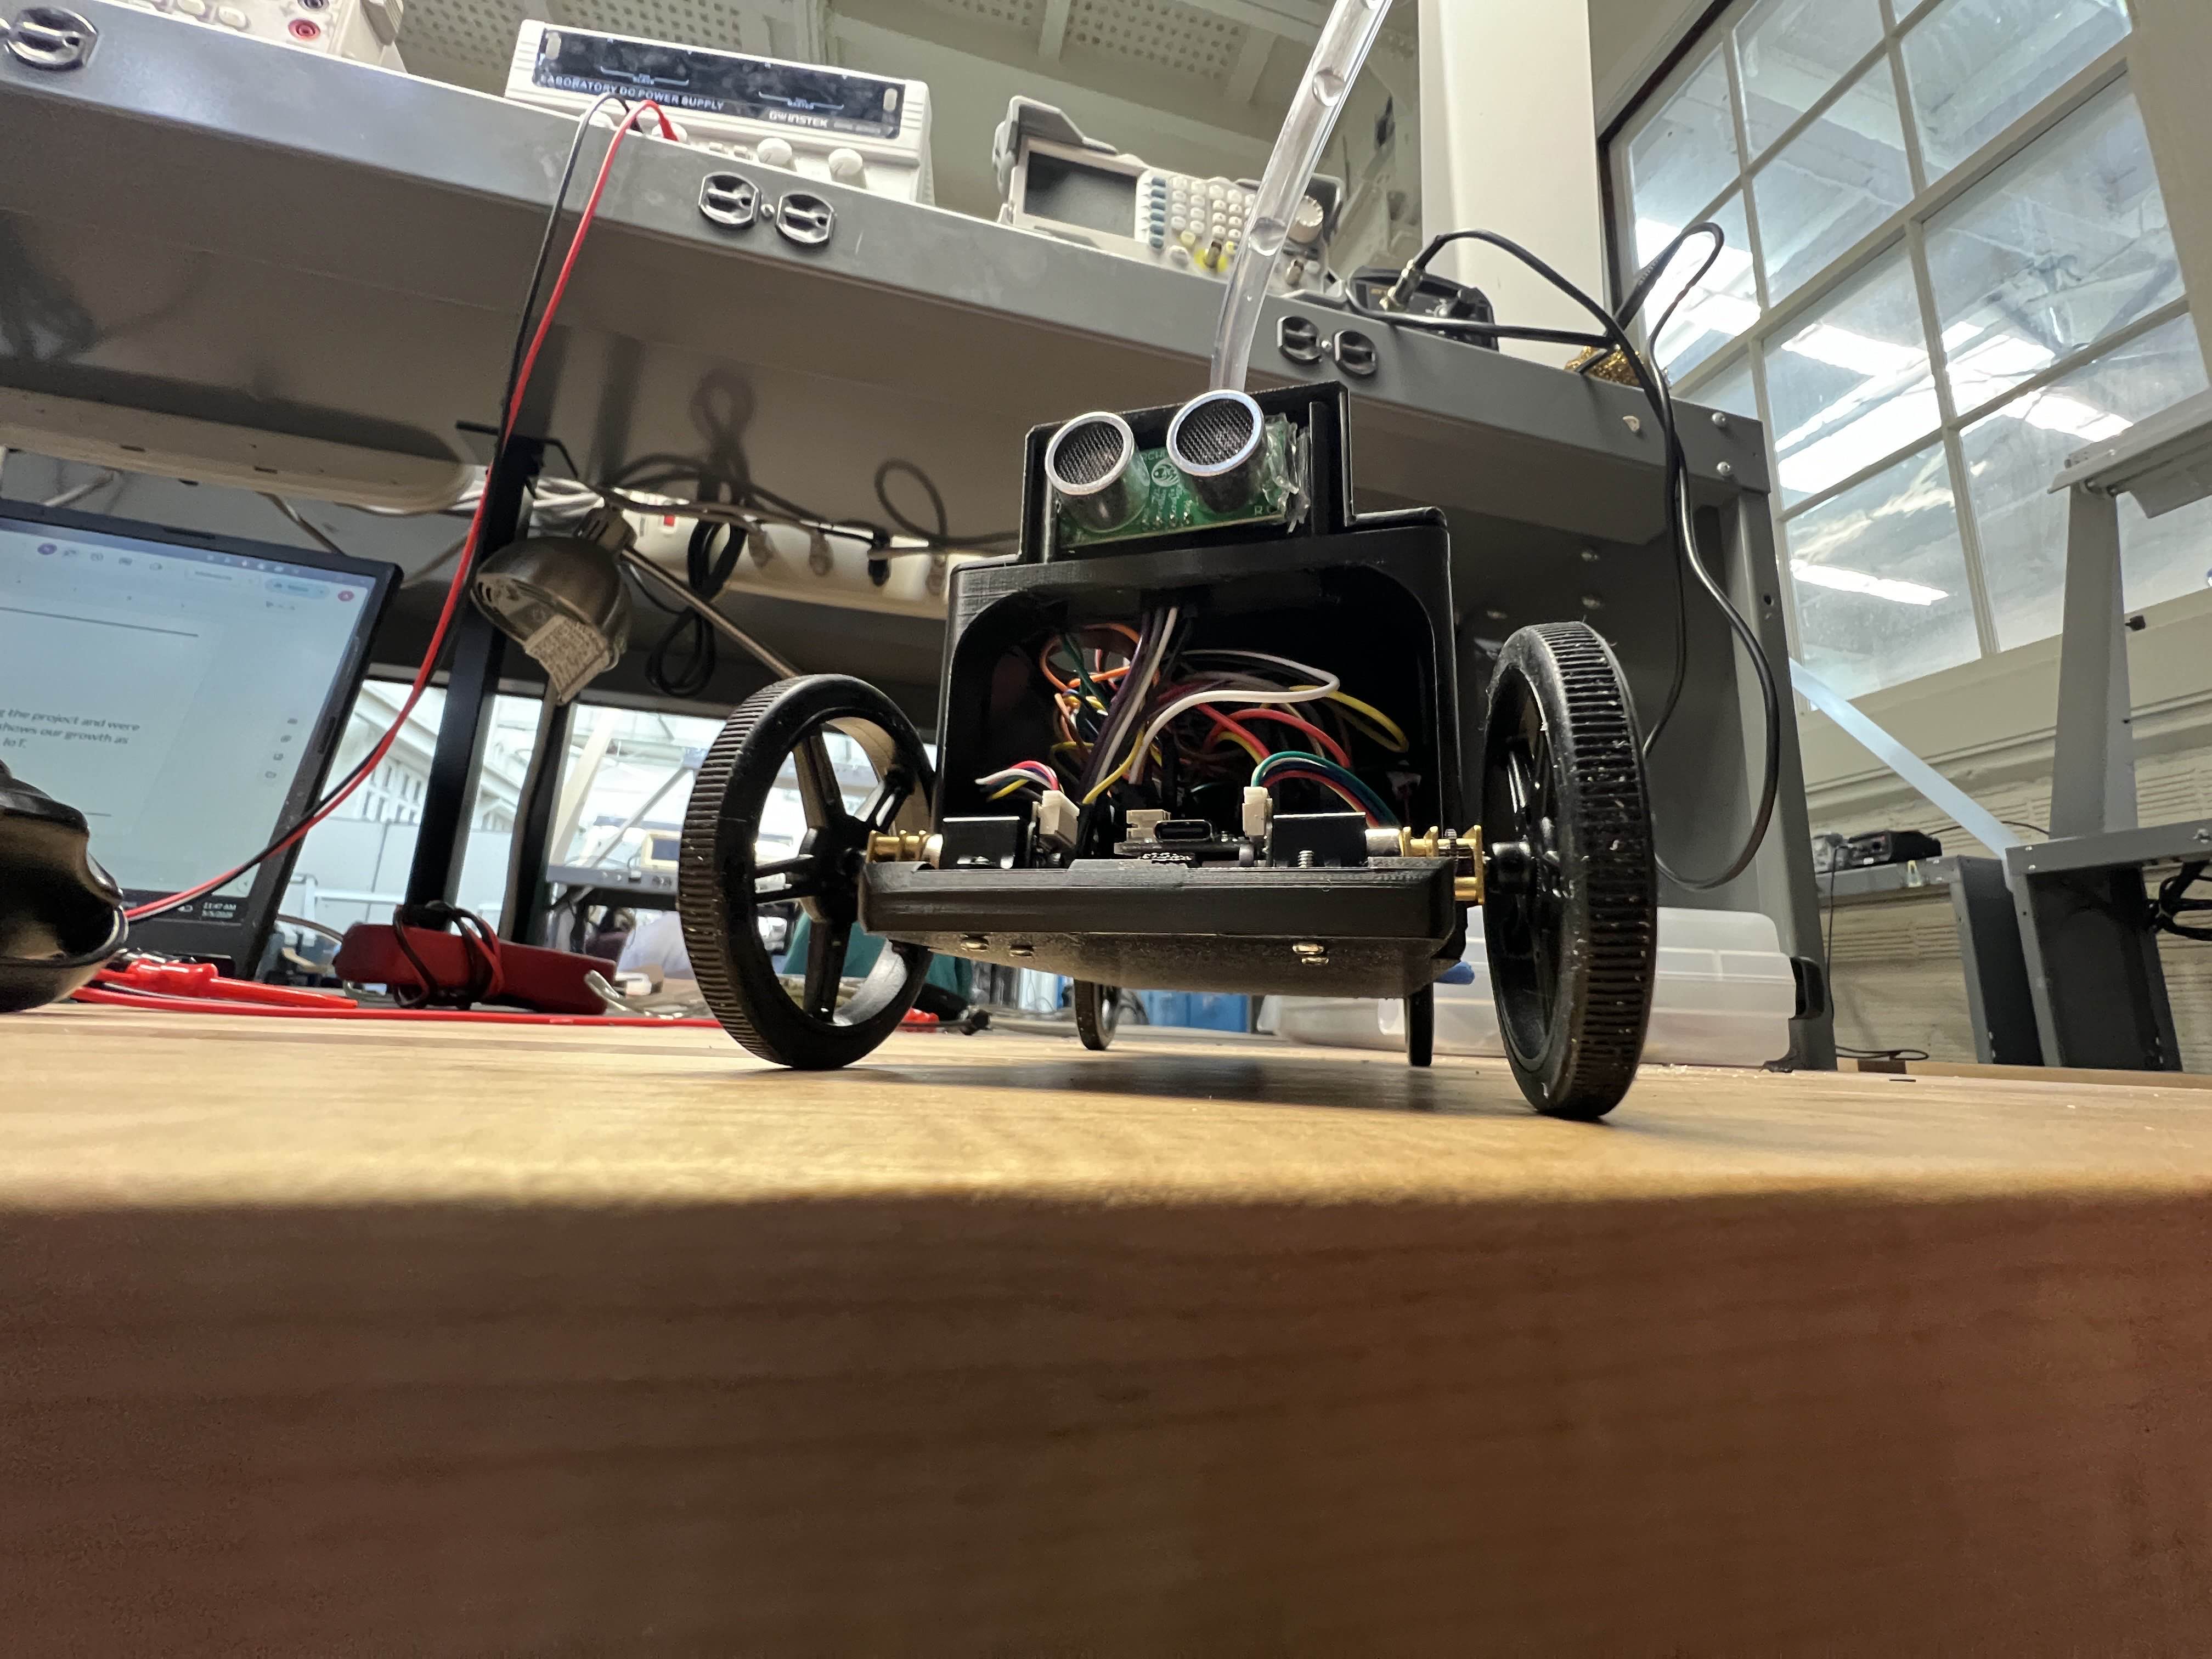
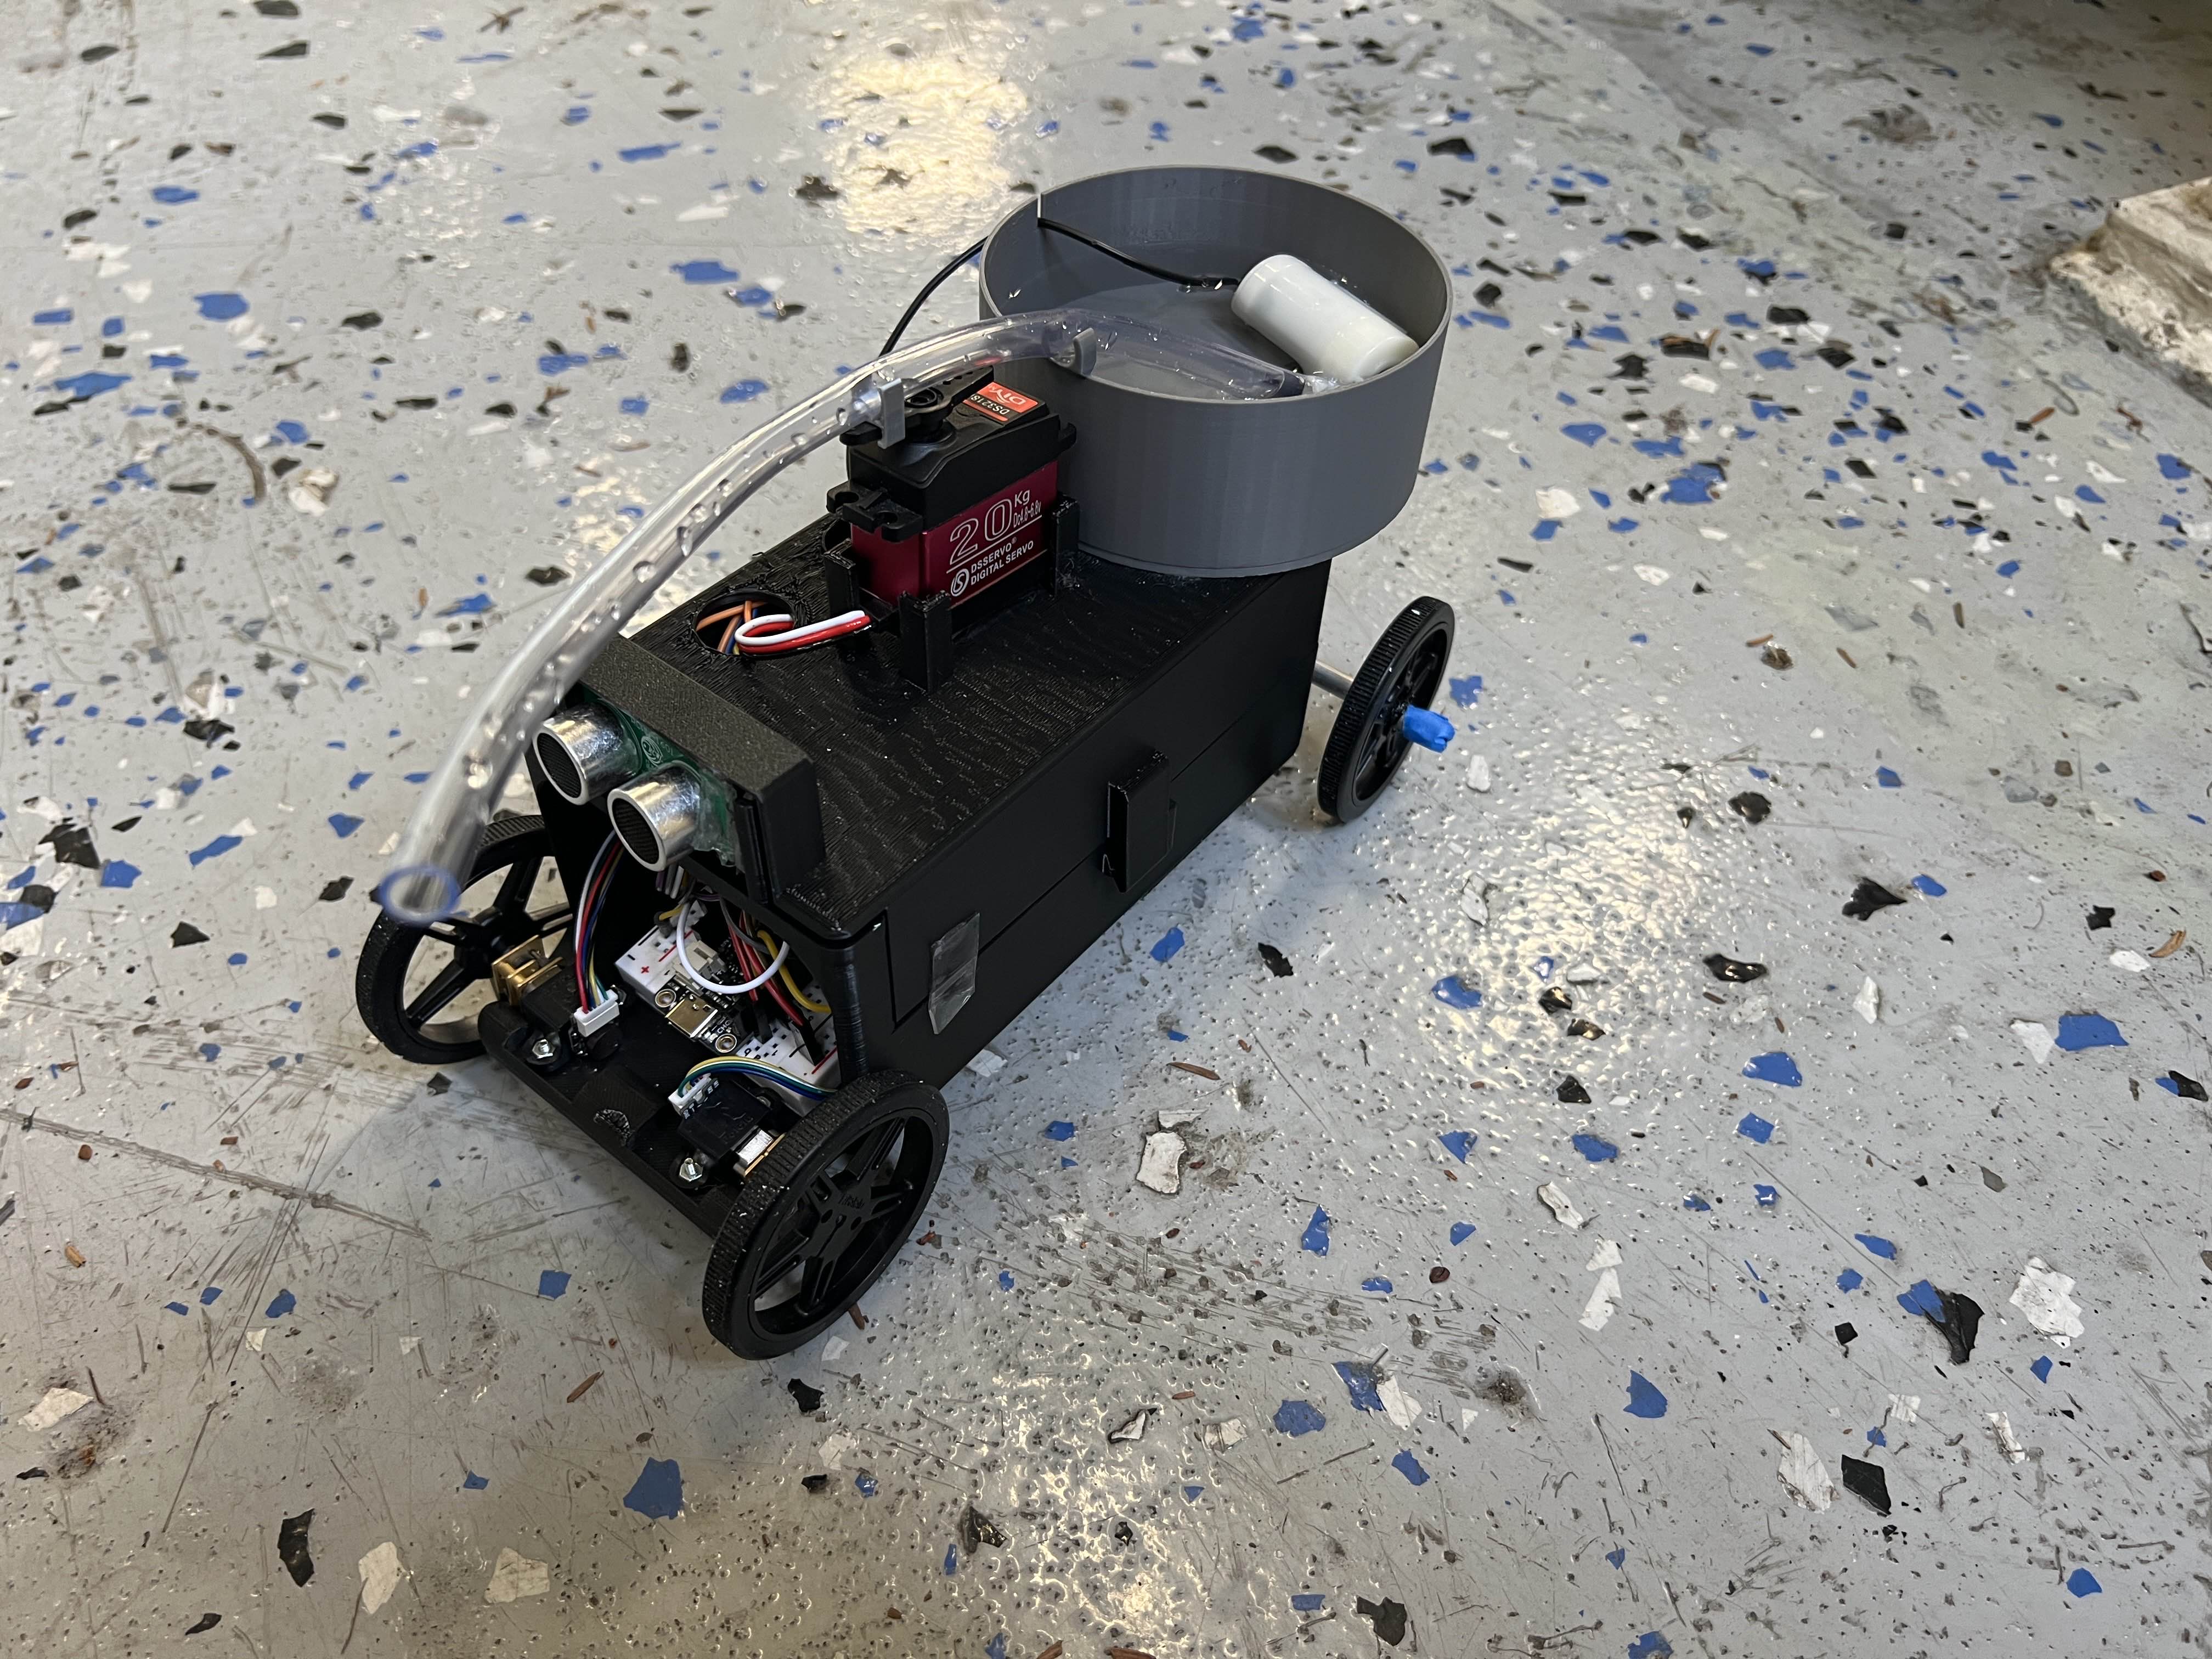
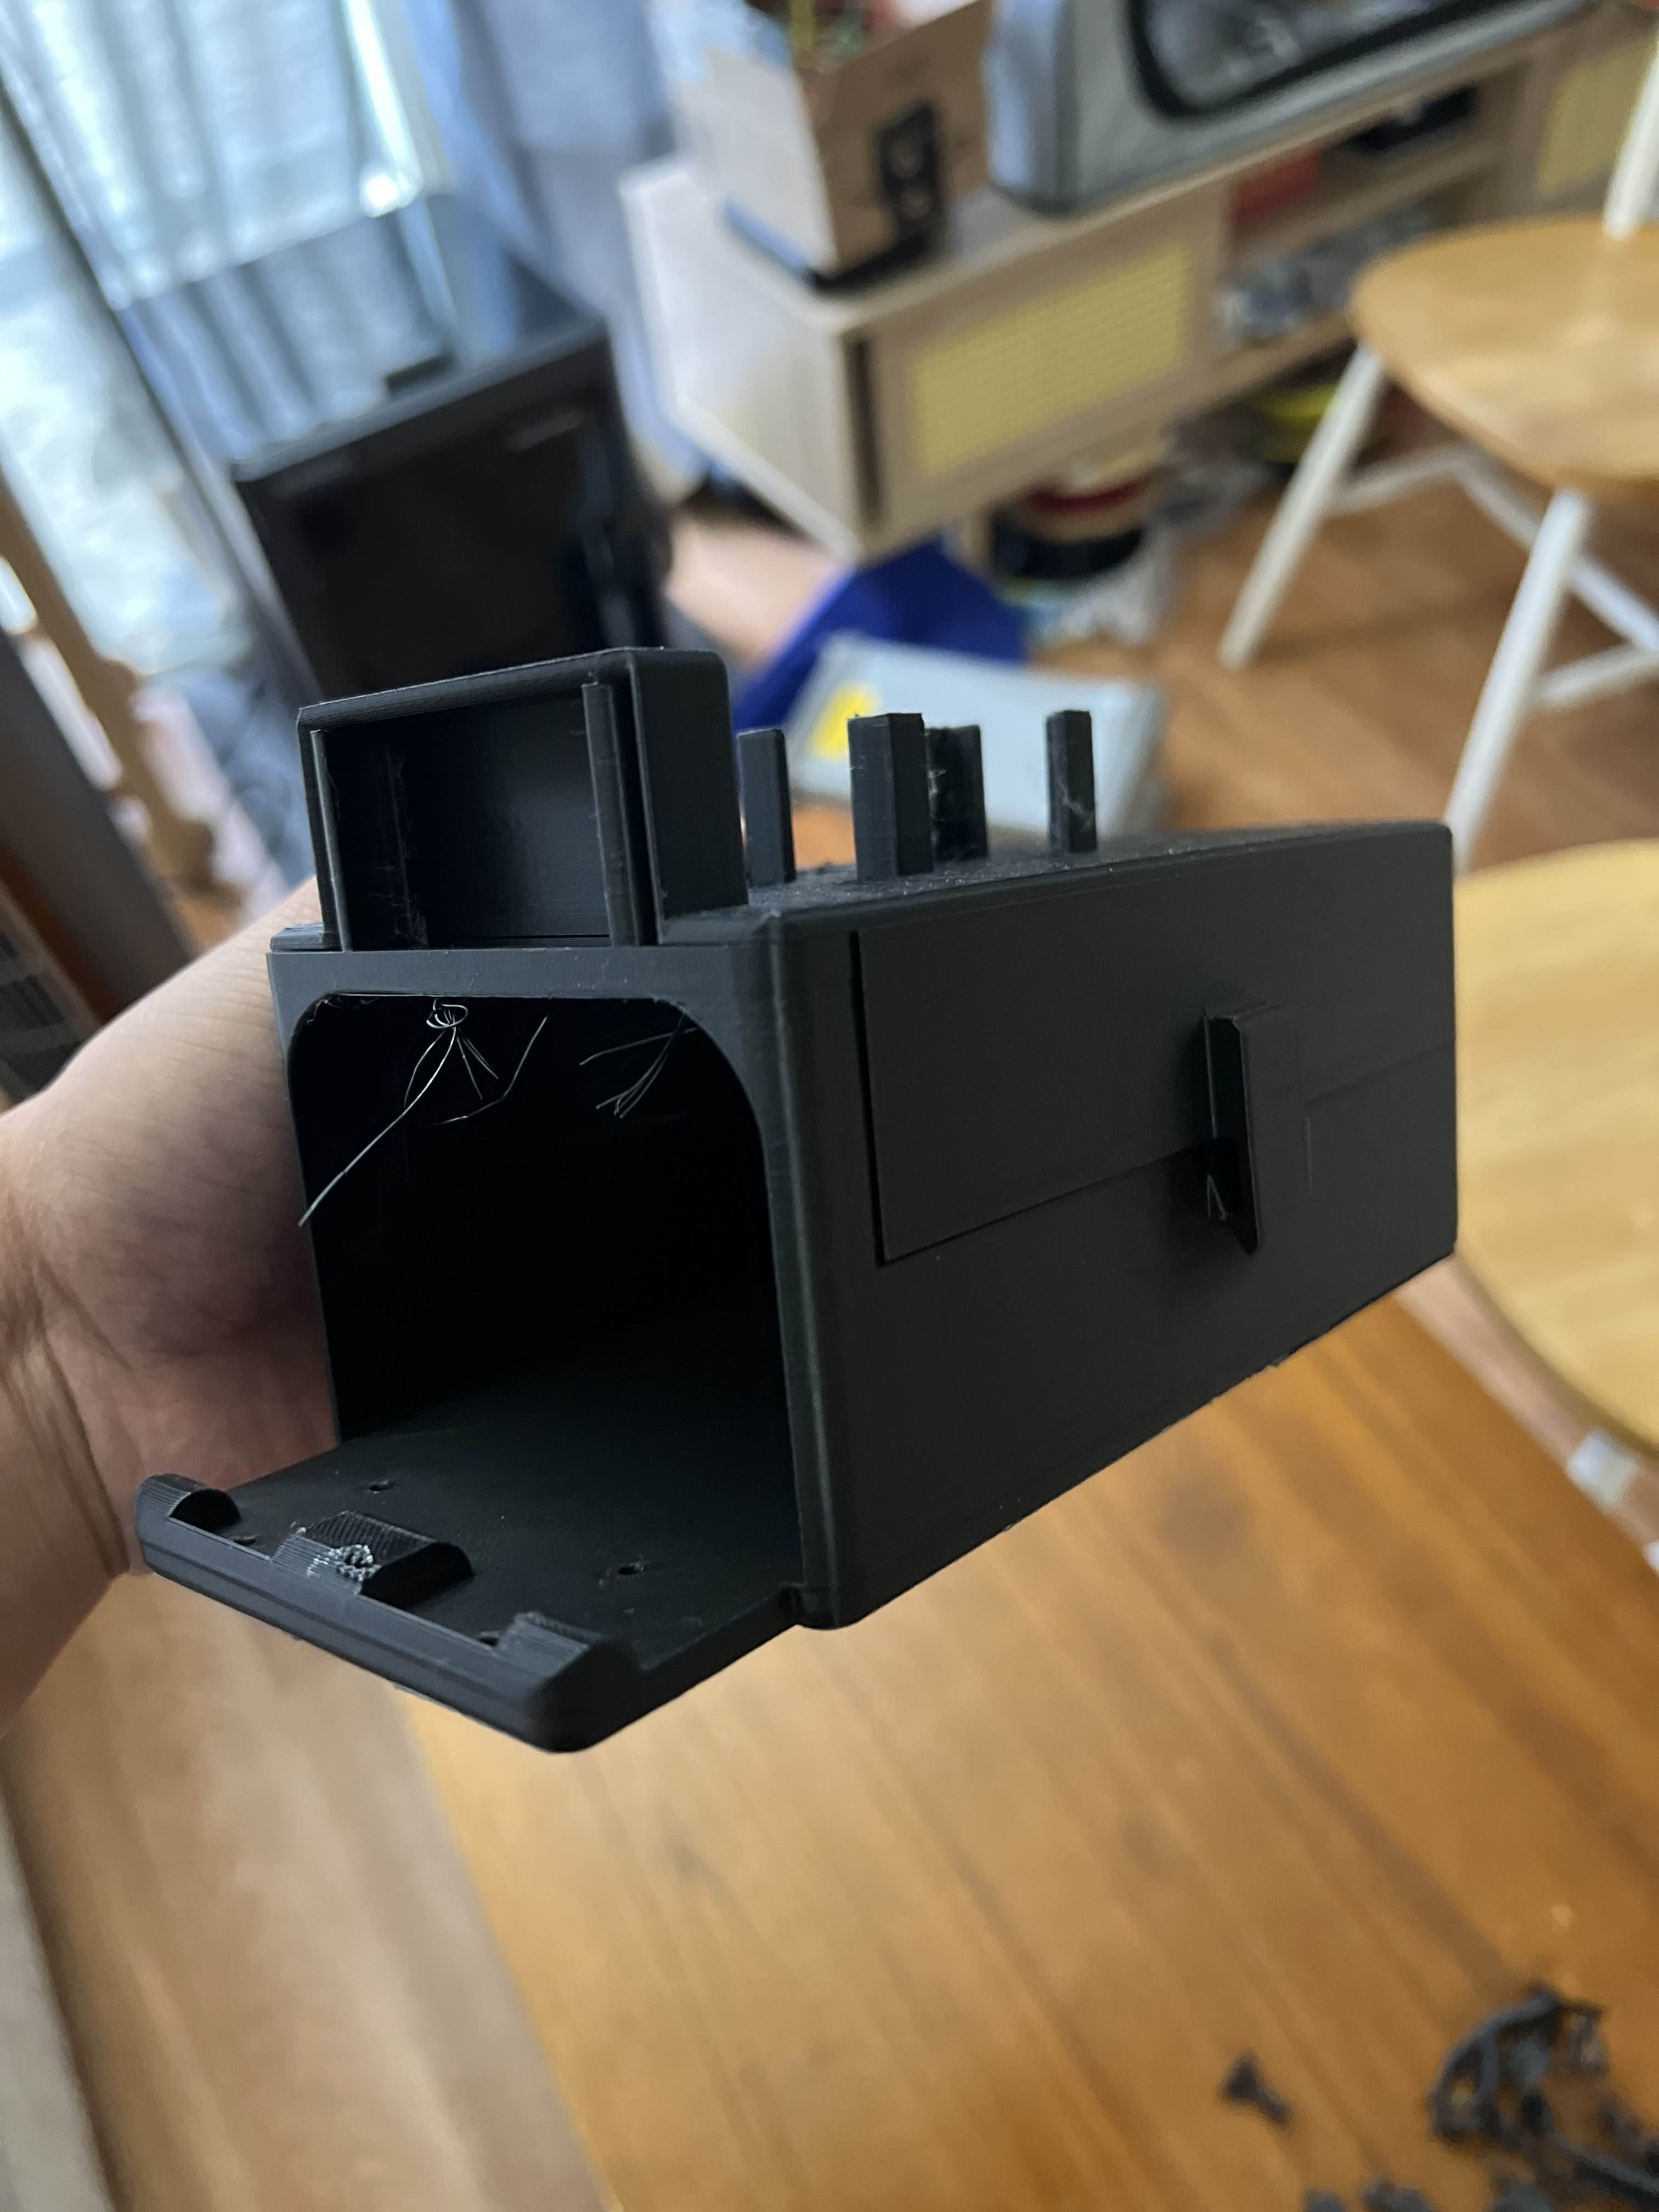
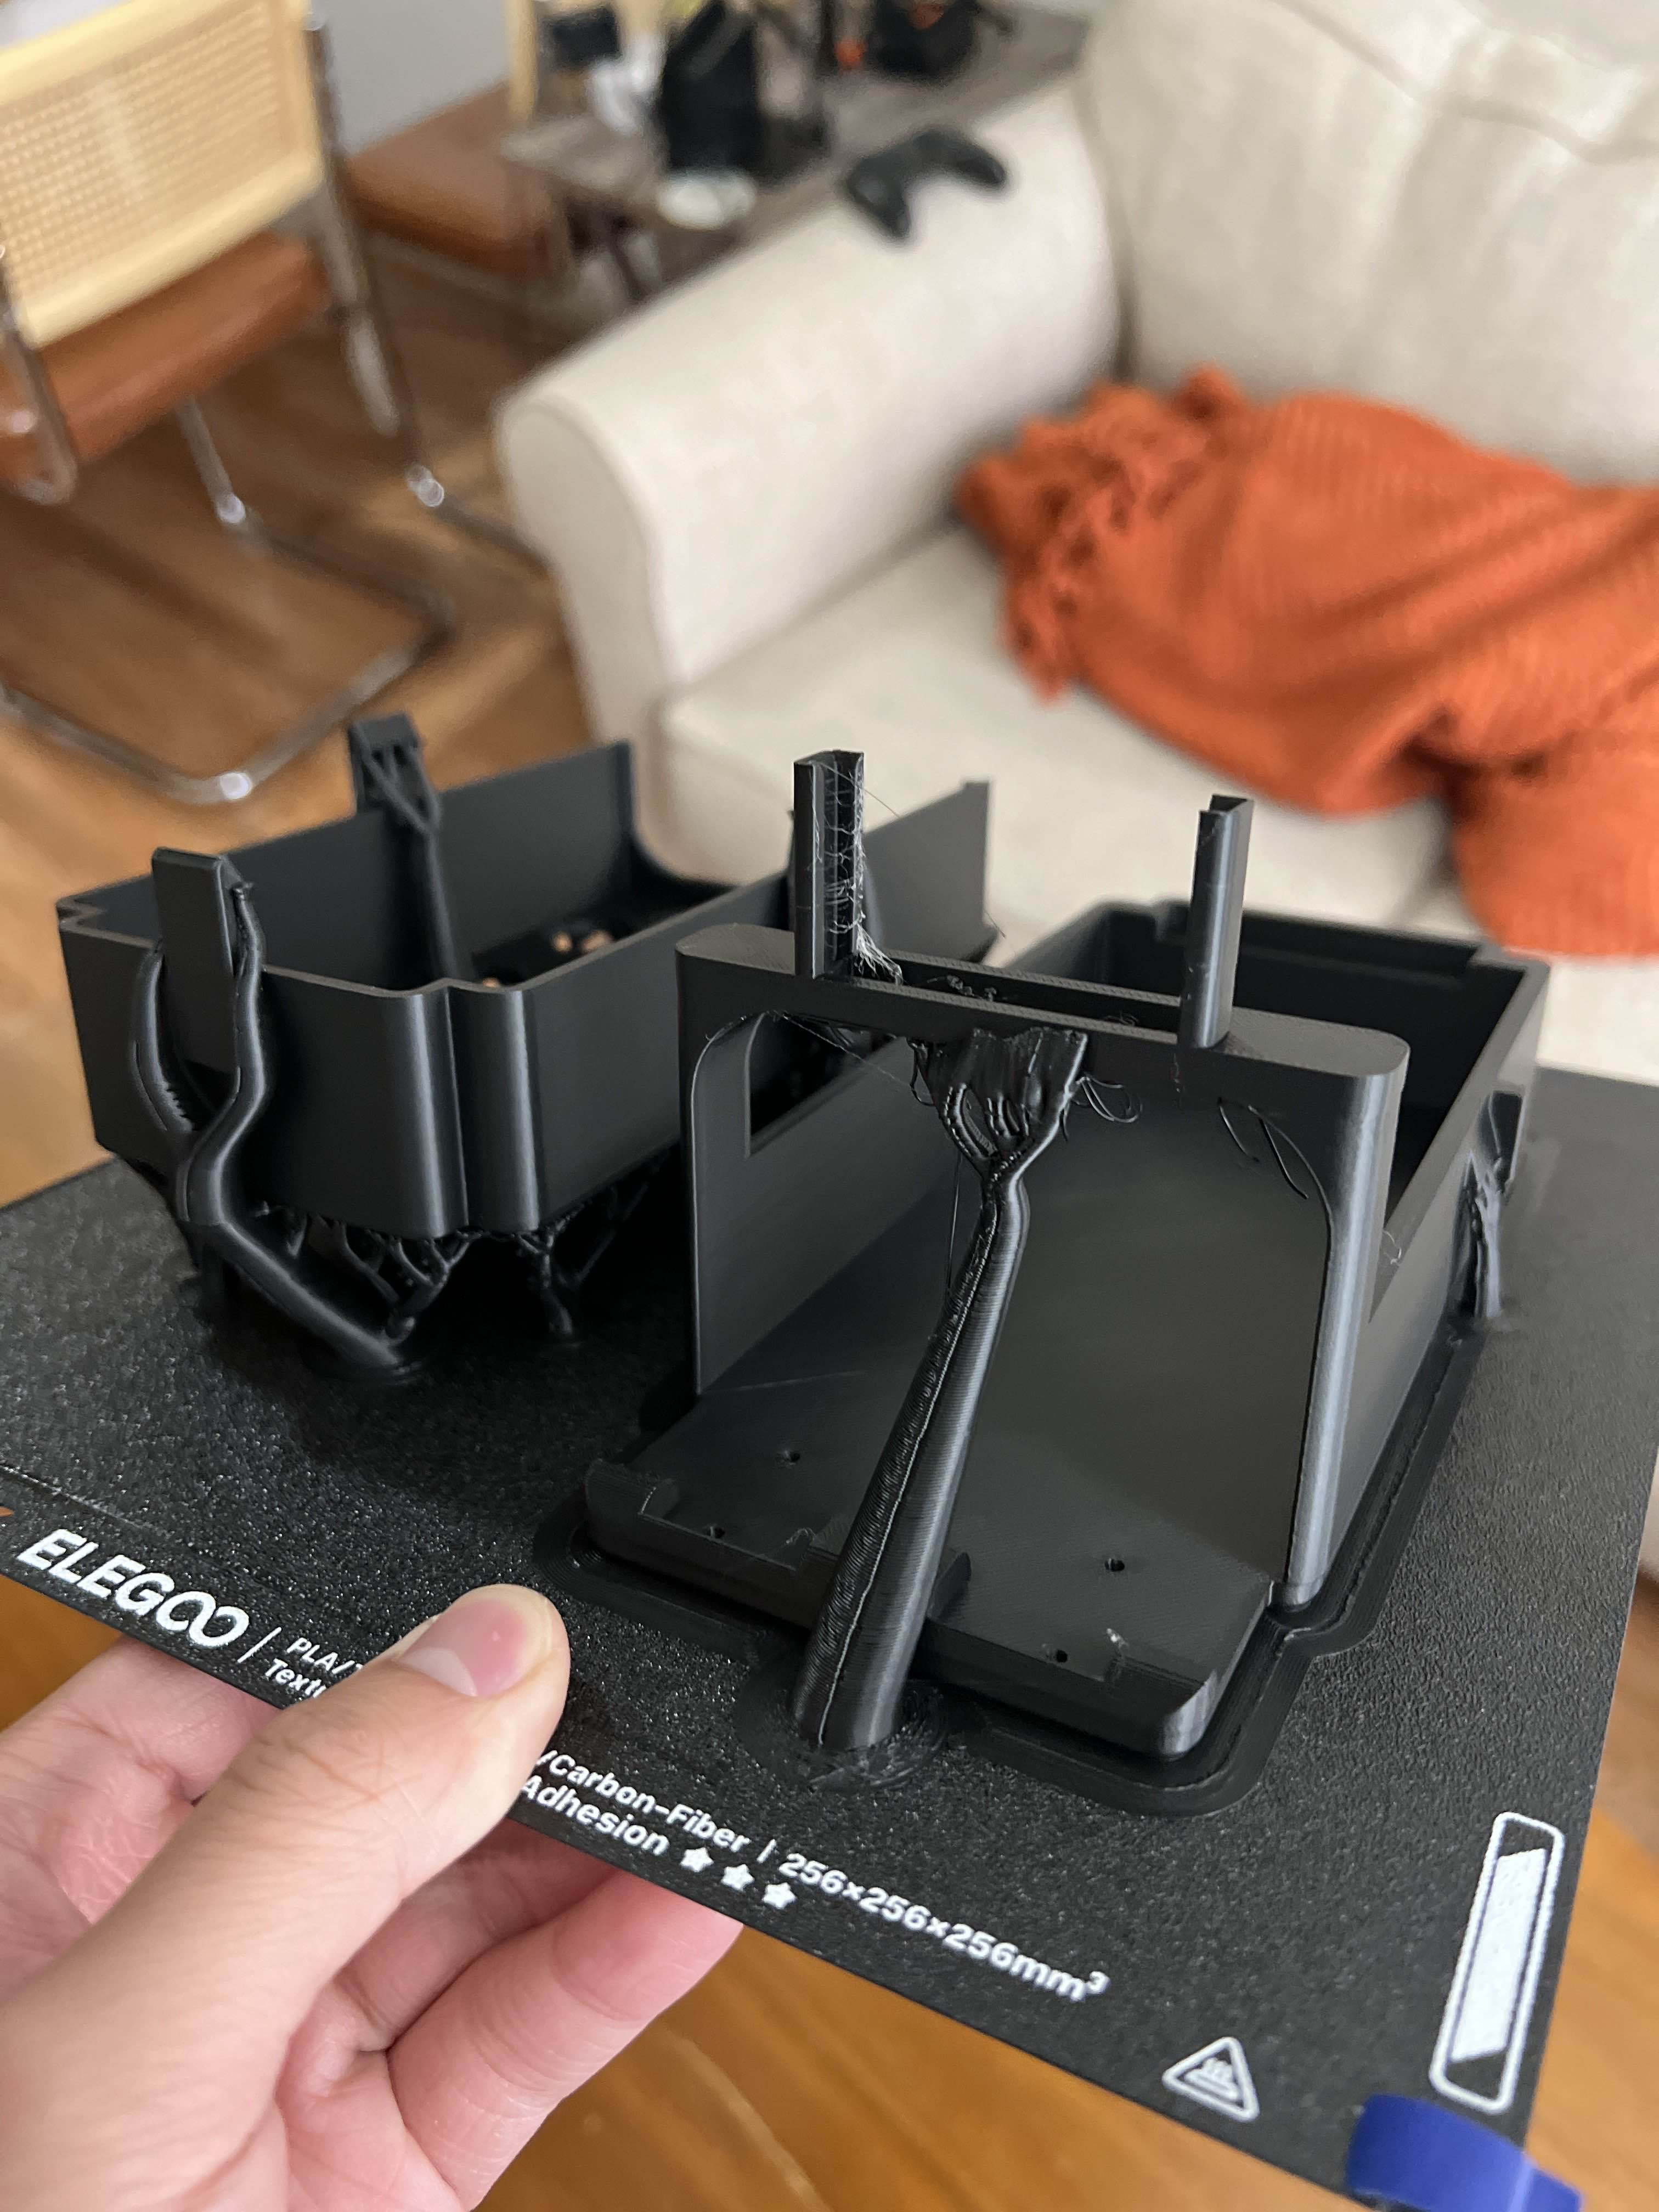
As part of a 3-person team in ME100, I helped design and build an RC rover concept for firefighting support, aimed at reducing human exposure to extreme heat and structural hazards during fire response. The vehicle featured a dual-mode control system: a remote-operated drive and turret-aiming mode, paired with an autonomous safety override that could act independently of the operator. I designed and fabricated the chassis in SolidWorks, integrating a servo-actuated water turret (180° range of motion), water pump, ultrasonic sensor, and IMU into a compact drivetrain platform. On the electronics side, I developed the ESP32 firmware, using a DRV8833 H-bridge for dual-motor drive control, an NMOS gate to enable PWM actuation of the water pump, and a MicroPython servo module for direct turret positioning. I implemented the autonomous safety logic, using real-time ultrasonic distance readings to automatically brake the drivetrain within 10 cm of an obstacle, and built the Blynk-based mobile interface for joystick driving, pump control, turret aiming, and live sensor telemetry. One of the more interesting problems I solved was electromagnetic interference between the water pump and servo motor, both inductive loads sharing a power system; I resolved it by isolating motor grounding to a single reference point and adding suppression capacitors and a flyback diode. I also redesigned the power distribution after our initial single-USB-power approach proved insufficient, splitting actuators onto dedicated Li-Po supplies.
Project Images